Orbbec Gemini 305 Stereo Vision Camera
Highlights
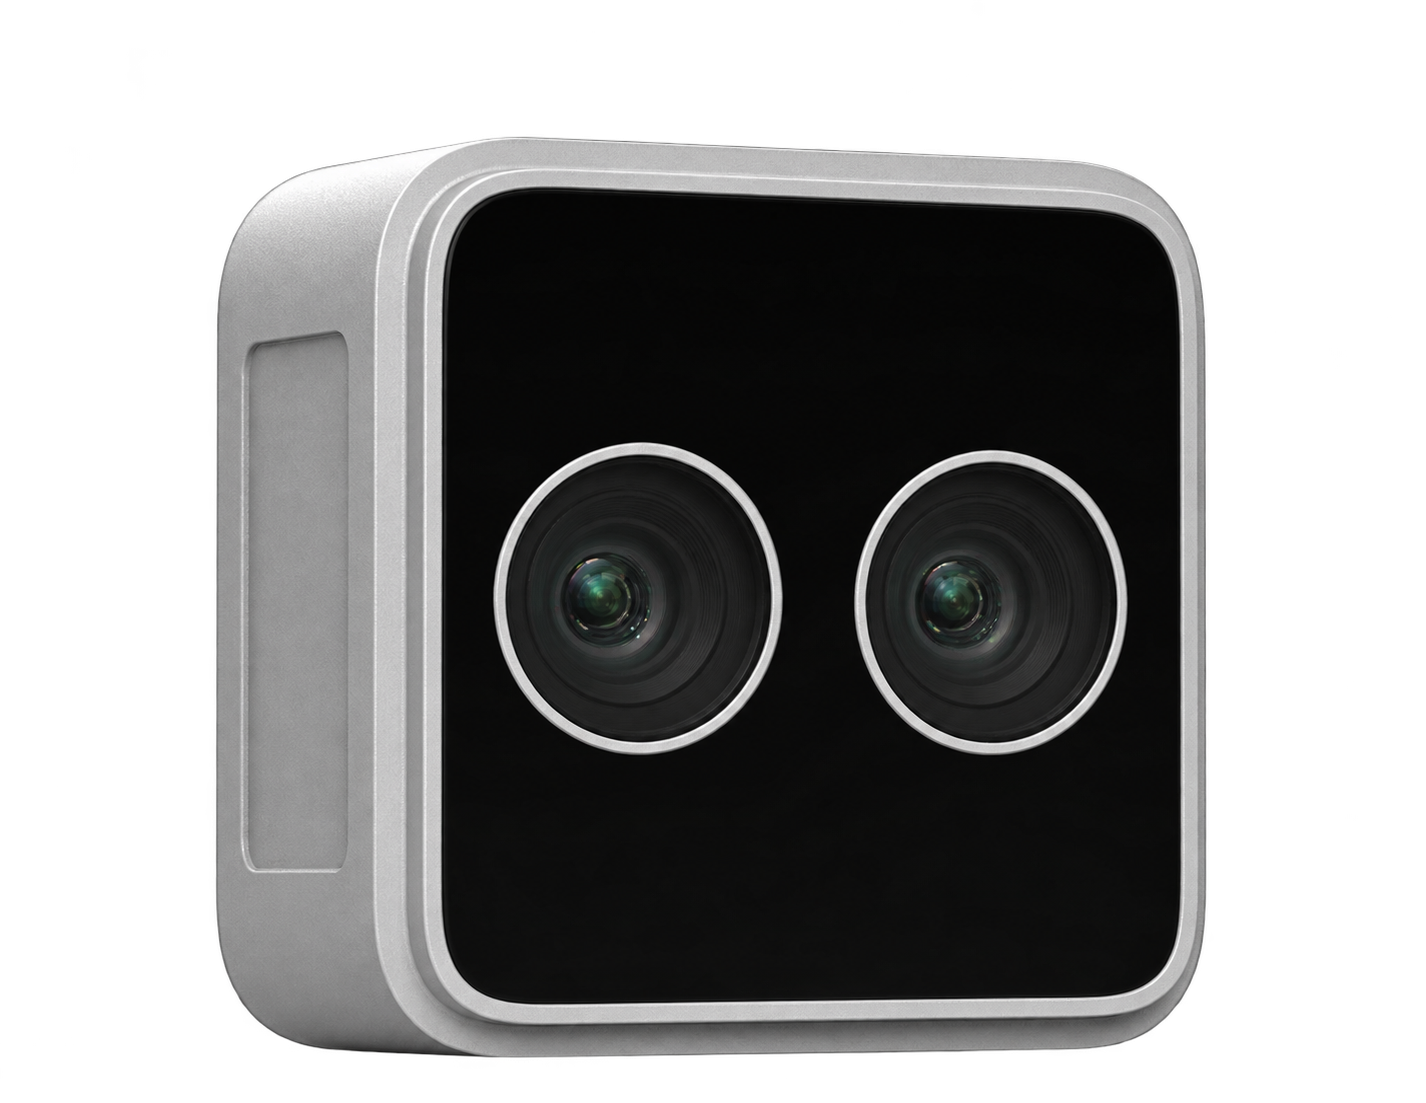
Orbbec Gemini 305 is an ultra-compact passive stereo vision camera designed specifically for robotic wrist mounting, close-range manipulation, and precision grasping. Its 18 mm stereo baseline, global-shutter color sensors, and lightweight 68 g housing allow installation directly on cobots, humanoid robot hands, and other payload-sensitive end-of-arm systems.
The Gemini 305 provides depth resolution up to 1280 × 800 at 30 fps, a specialized 4 cm to 100 cm+ operating range, and an optimal working range of 7 cm to 50 cm. It combines a wide 88° × 65° depth field of view with sub-millimeter close-range capability, synchronized RGB-D imaging, and hardware or software multi-camera synchronization.
Features
4 cm Ultra-Close Depth
— Captures depth and color at extremely short working distances for precise robotic grasping and manipulation.
— Captures depth and color at extremely short working distances for precise robotic grasping and manipulation.
Ultra-Compact Wrist-Mount Design
— A 42 × 42 × 23 mm, 68 g housing minimizes payload and space requirements on robotic wrists and end effectors.
— A 42 × 42 × 23 mm, 68 g housing minimizes payload and space requirements on robotic wrists and end effectors.
Global-Shutter Stereo Color
— Global-shutter sensors reduce motion distortion during fast robotic arm and object movement.
— Global-shutter sensors reduce motion distortion during fast robotic arm and object movement.
MX6800 Depth Processing
— Integrated Orbbec processing provides real-time depth output while reducing host-compute requirements.
— Integrated Orbbec processing provides real-time depth output while reducing host-compute requirements.
Flexible RGB-D Imaging
— Supports depth plus color and dual-color operating modes with spatial and temporal depth-to-color alignment.
— Supports depth plus color and dual-color operating modes with spatial and temporal depth-to-color alignment.
Hardware & Software Synchronization
— Supports multi-camera synchronization and external triggering for coordinated robotic vision systems.
— Supports multi-camera synchronization and external triggering for coordinated robotic vision systems.
Applications
|
Cobots
|
Humanoid Robots
|
Pick & Place
|
Robotic Grasping
|
|
End-of-Arm Vision
|
Hand-Eye Coordination
|
Robotic Inspection
|
Robotic Manipulation
|
Product Specifications